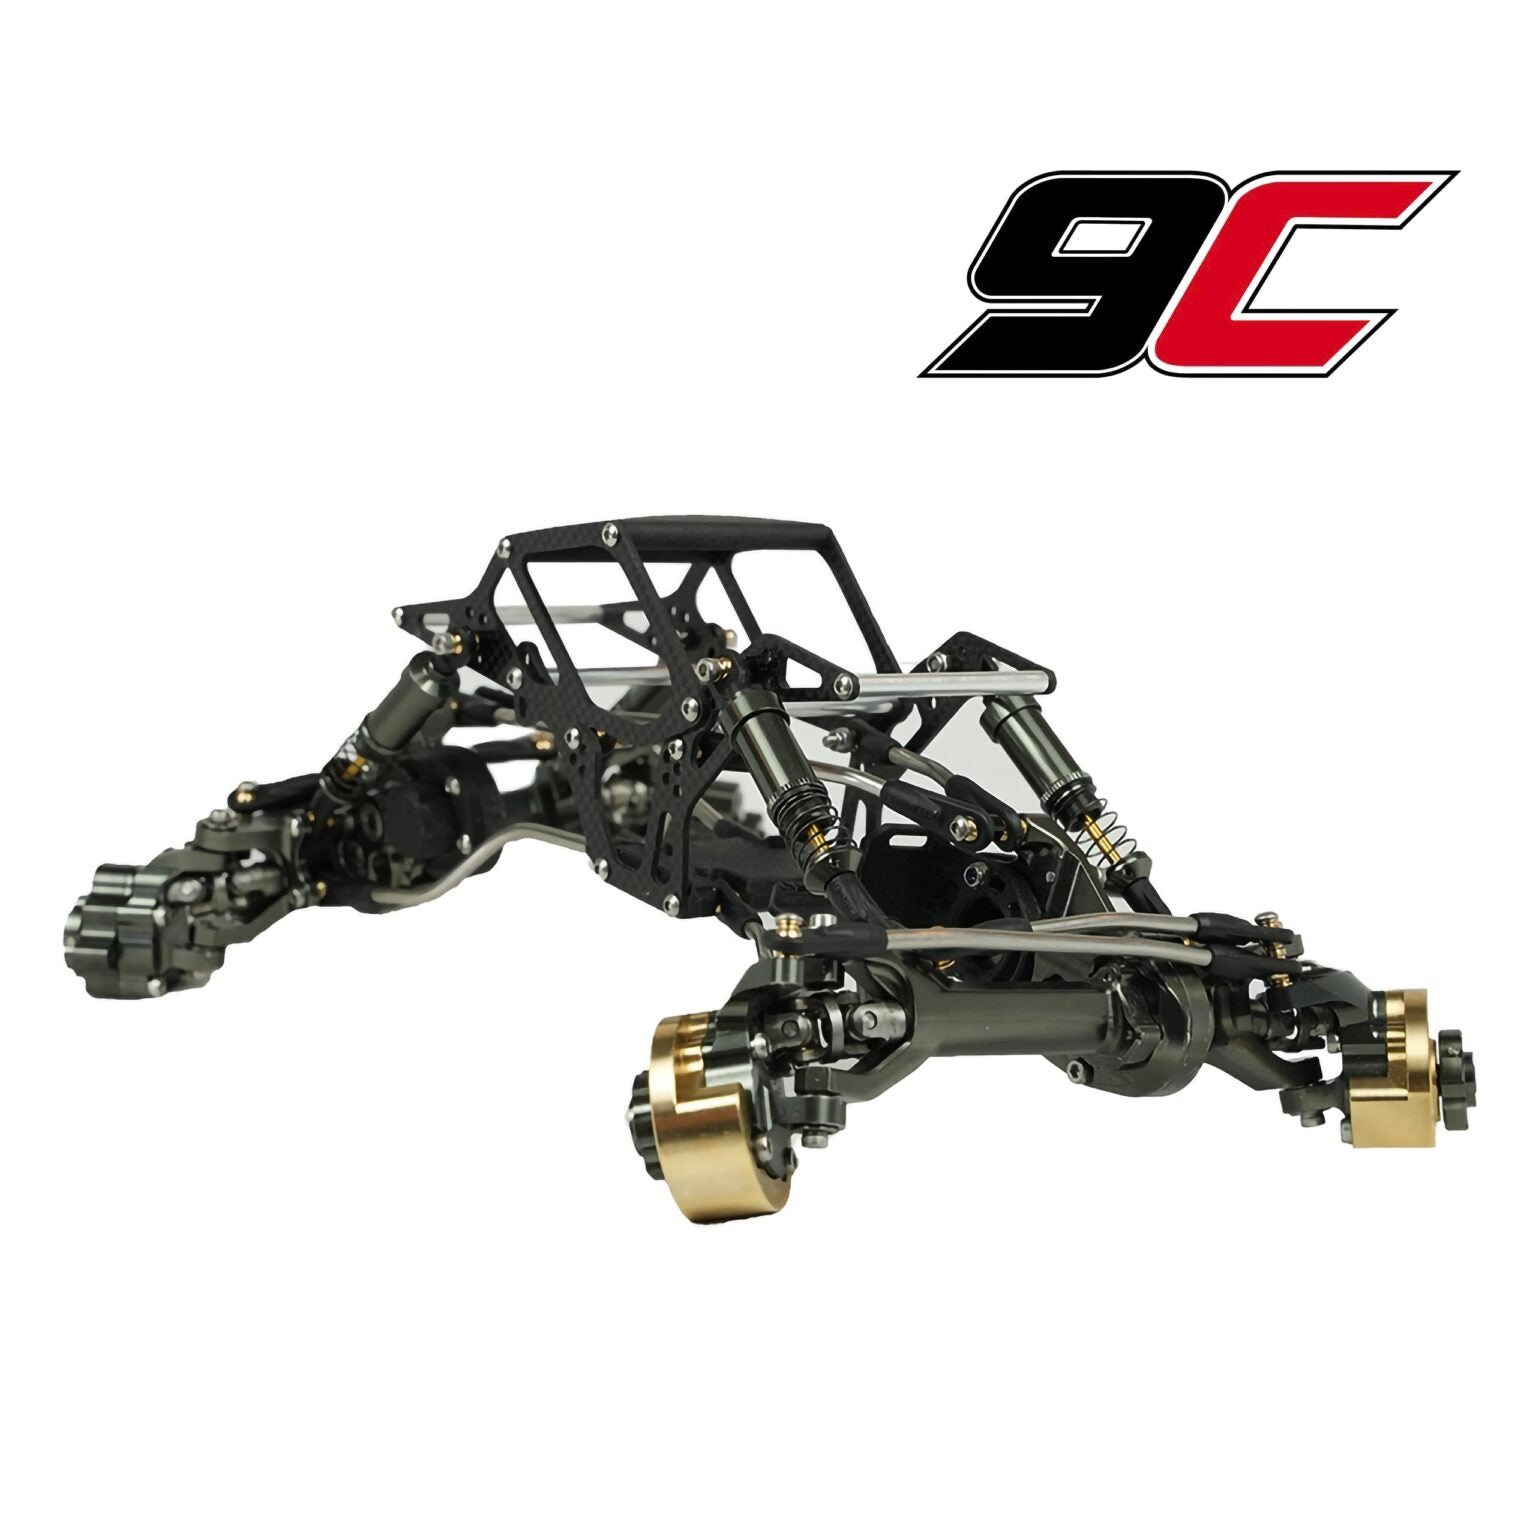


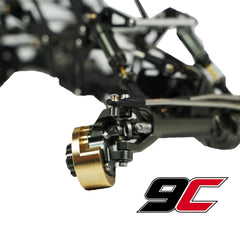
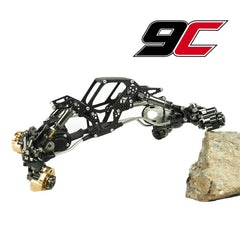
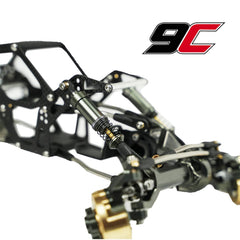


9C MONTY 4WS MOA 1/10 SCALE COMPETITION CRAWLER
Vendor:
9C
SKU:
9C-M
- $999.99
- $999.99
- Unit price
- per


A competition crawler small enough to walk in on your back and stubborn enough to finish the line once you get there.
Steering: 60°+, front and rear
Drivetrain: MOA · 4WS
Portals: Highest gearing on the market
Chassis: Carbon fibre
Shocks: 85 mm high-performance
Motors: 380 · 36 mm (2-in-1)
( Sold as a slider / Build guide )
Recommended electronics and accessories.
Monty ships as a complete rolling chassis — chassis, axles, shocks, electronics mounts and hardware — but without the parts below. You choose and supply them yourself, so you can build Monty exactly the way you want and reuse gear you may already own. Every option in this guide is verified to work together.
- Radio system (transmitter + receiver)
- Drive motors (front + rear) and ESC(s), or 2-in-1 units
- Steering servos + servo horns
- Wheels and tires
I/ Radio System (TX/RX)
Monty uses independent front and rear motors (MOA) plus 4-wheel steering (4WS), so your radio system needs enough channels and mixing capability to drive it properly.
| Channel | Function |
|---|---|
| CH1 | Front steering |
| CH2 | Front ESC |
| CH3 | Rear ESC |
| CH4 | Rear steering |
- Minimum 4 channels, mapped as in the table above.
- Receiver: must output at least 4 independent channels.
- Transmitter: must support curve-based channel mixing (e.g. EdgeTX or equivalent) so a single pot or switch can blend front/rear throttle across the full Dig → 4WD → Burn range. The Sanwa/Airtronics MT-4 is a good option with MOA mixing built in, or an EdgeTX stick radio like the Radiomaster Pocket.
- 4WS can run independently on CH4 or be mixed with steering, depending on your preference and your transmitter's mixing options.
Monty is a competition crawler small enough to walk in on your back and stubborn enough to finish the line once you get there.
Motor on axle at both ends, four-wheel steering, portal reduction and a carbon chassis — every choice made to keep the contact patch loaded and the drivetrain calm.
II/ Motors & ESCs
Monty is a true MOA (motor-on-axle) platform with independent motors front and rear. You need 2 complete drive units — one per axle (2 motors + 2 ESCs, or 2 matching 2-in-1 units). It is built around modern compact brushless motors rather than legacy 540-style motors; the same combo is normally used on both axles.
All pinions are 48 DP (diametral pitch) — confirm your pinion and gear mesh use matching 48DP hardware. A few known-good combos (not an exhaustive list):
| # | Motor | ESC / 2-in-1 | Pinion range (48DP) | Notes |
|---|---|---|---|---|
| 1 | Furitek Unity 1800 | Built-in 2-in-1 | 17T – 22T (minimum 17T) | Compact 2-in-1, no separate ESC needed |
| 2 | Furitek Unity 2300 | Built-in 2-in-1 | 17T – 22T (minimum 17T) | Compact 2-in-1, no separate ESC needed |
| 3 | Dlux Stumpy | Small brushless ESC | 15T – 22T | Pairs with any small-form-factor brushless ESC |
| 4 | Furitek Dynamik 380 | Furitek Python X | 15T – 22T | — |
| 5 | Furitek Dynamik 3800 | Furitek Python UTB18 | 15T – 22T | — |
| 6 | Hobbywing Mini16 (2-in-1) | Built-in 2-in-1 | 13T (fixed) | Requires a 3D-printed adapter — STL provided free by 9C RC. Must use the special Axial Capra UTB18-style 13T pinion |
| 7 | Generic 36 mm outrunner | Any matching brushless ESC | 18T – 22T (minimum 18T) | Covers common generic/off-brand 36 mm-diameter outrunner motors |
Rule of thumbConfirm the pinion you buy is 48DP and falls inside the range listed for your motor before ordering — pinions outside these ranges either won't fit the gear mesh correctly or won't clear the axle housing.
ImportantAfter mounting each pinion, check that the in-axle transmission still spins freely by hand. A mismatched or misaligned pinion can bind the gear mesh and damage the transmission.
Motor guardsMost of these motors are open-can outrunners (exposed bells and magnets), so a motor guard is a good idea against rock strikes and debris. 9C RC also provides a free, 3D-printable front skid plate STL that can be used instead of a classic motor guard.
III/ Steering Servo & Servo Horn
Monty accepts standard low-profile servos — no special servo required. You need 2 low-profile servos — one per axle (front steering + rear steering) to run 4WS.
Recommended minimum torque: at least ~40 kg·cm. These examples are all at or above that baseline:
- JX B40
- Reefs 800LP
- AGFRC A66FHLW
- NSDRC RS650 High Torque Low Profile (46–80 kg·cm depending on voltage)
Servo hornA 25 mm servo horn is recommended for correct steering throw.
Powering the servos (BEC = Battery Eliminator Circuit, which regulates power to the servo) — choose one of:
- Split BEC — use the front ESC's BEC for the front servo and the rear ESC's BEC for the rear servo.
- A single external BEC rated at least 10A.
- Direct power — servo wired straight to the battery/ESC power rail, bypassing a BEC. For example the NSDRC RS700 V2 High Torque Low Profile Brushless Servo (46–80 kg·cm, 8.4–16.8V direct-power range, not routed through a BEC).
Safety noteNever plug both ESCs' BEC positive (red) wire into the receiver at the same time — two BECs feeding the same rail can fight each other and damage the ESCs or receiver.
IV/ Battery
Recommended: GNB 380mAh 3S LiPo (20 × 17 × 55 mm, ~32 g — compact "shorty" format).
Connecting one battery to two ESCs: Monty's front and rear drive units each have their own ESC, but there is only one battery — so both ESC power leads need to be joined into a single battery connector. We recommend standardising on XT30 plugs throughout (battery, ESCs and harness) to keep this simple. You have two options:
- Buy a ready-made Y-harness (parallel connector) matching your connector type (XT30 recommended). Plug each ESC into one side; the single end goes to the battery. The easiest option for first-time builders — no soldering required.
- Solder your own Y-harness — if you can't find a pre-made one for your connector type, splice both ESC power leads together into a single battery connector. Make sure + goes to + and – goes to – on both sides, and insulate the joints with heat-shrink or electrical tape.
Either way, the result is the same: one battery plug feeding both ESCs in parallel.
V/ Wheels & Tires
Wheel fitment rule: any 1.9" or 2.2" wheel using the VP 6-screw (6-lug) bolt pattern will bolt on — you are not locked into one brand.
- Best choice: high-clearance, comp-style wheels.
- Best choice: narrow-offset rims make the most sense on Monty's width.
- Example: Dlux 1.9" and 2.2" rims fit well — many other generic 1.9"/2.2" VP-pattern wheels also work.
- Tuning tip: heavier wheels up front and lighter ones in the rear is a useful weight-distribution trick for better front traction when climbing.
Tire size range: 4.19" to 4.75" diameter, in both 1.9" and 2.2" fitments. A few examples known to work well — not an exhaustive list; any tire in this range should fit:
| Tire | Size | Fits |
|---|---|---|
| Reefs Scrubs | 4.75" | 1.9" |
| RC4WD Baja MTZ Narrow | 4.6" | 2.2" |
| RC4WD Bully | 4.19" (small option) | 1.9" |
| INJORA XHX Pin Tires | 4.75" | 1.9" |
| JConcepts Ruptures | 4.75" | 1.9" and 2.2" |
1/Steering: 60°+ lock, front and rear
2/4WS: Four-wheel steering, independently driven
3/Driveshafts: Double-joint cardans for smooth steering
4/Portals: Highest gearing on the market
5/Drivetrain: MOA — motor on axle, front and rear
6/Chassis geometry: Optimised for balance and weight transfer
7/Shocks: 85 mm high-performance
8/Chassis material: Carbon fibre
9/Axles: Anodised, industrial-grade ENAW alloy
10/Motors: Fits 380 and 36 mm motors — 2-in-1 unity
11/Wheels: Prepared for Rockmagnet wheels
12/Options: Motor cover outrunners · low-profile servos
( 9C RC Competition Portal Axle )
Built aroundfour coretechnologies.
01/ 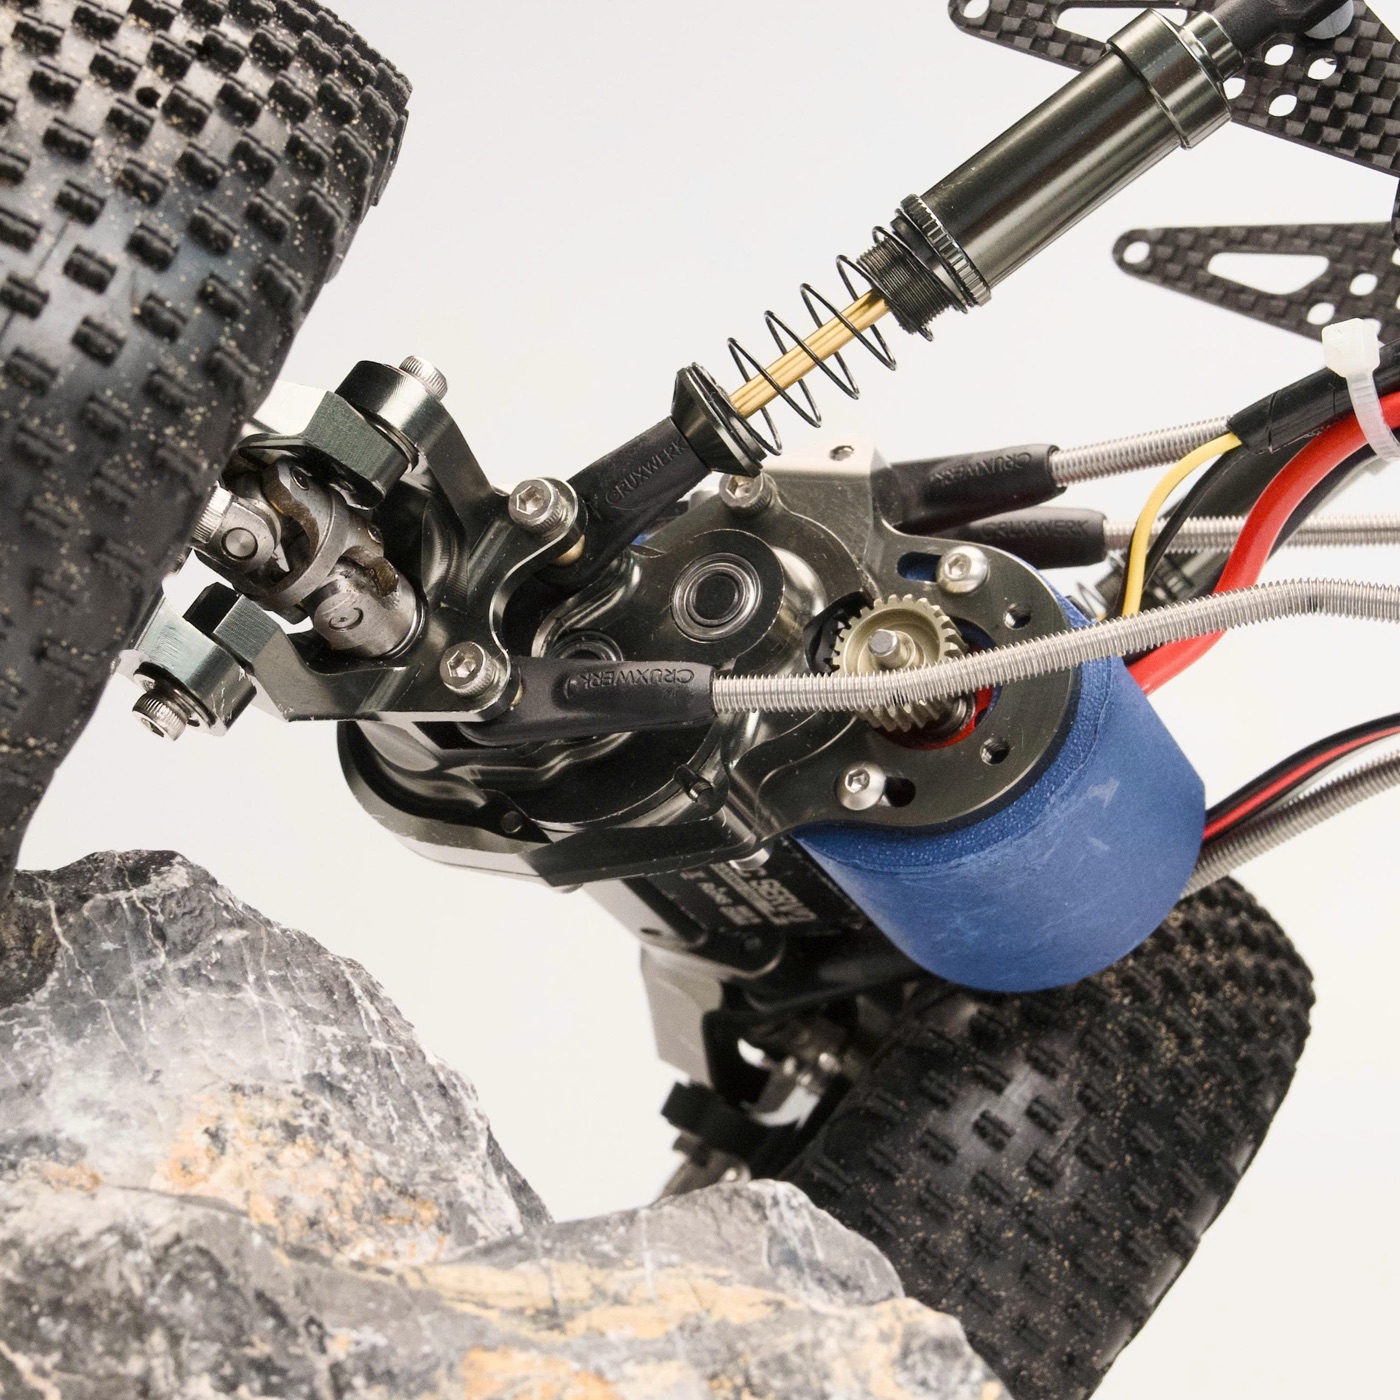 02/
 03/
 04/
60°+ Steering
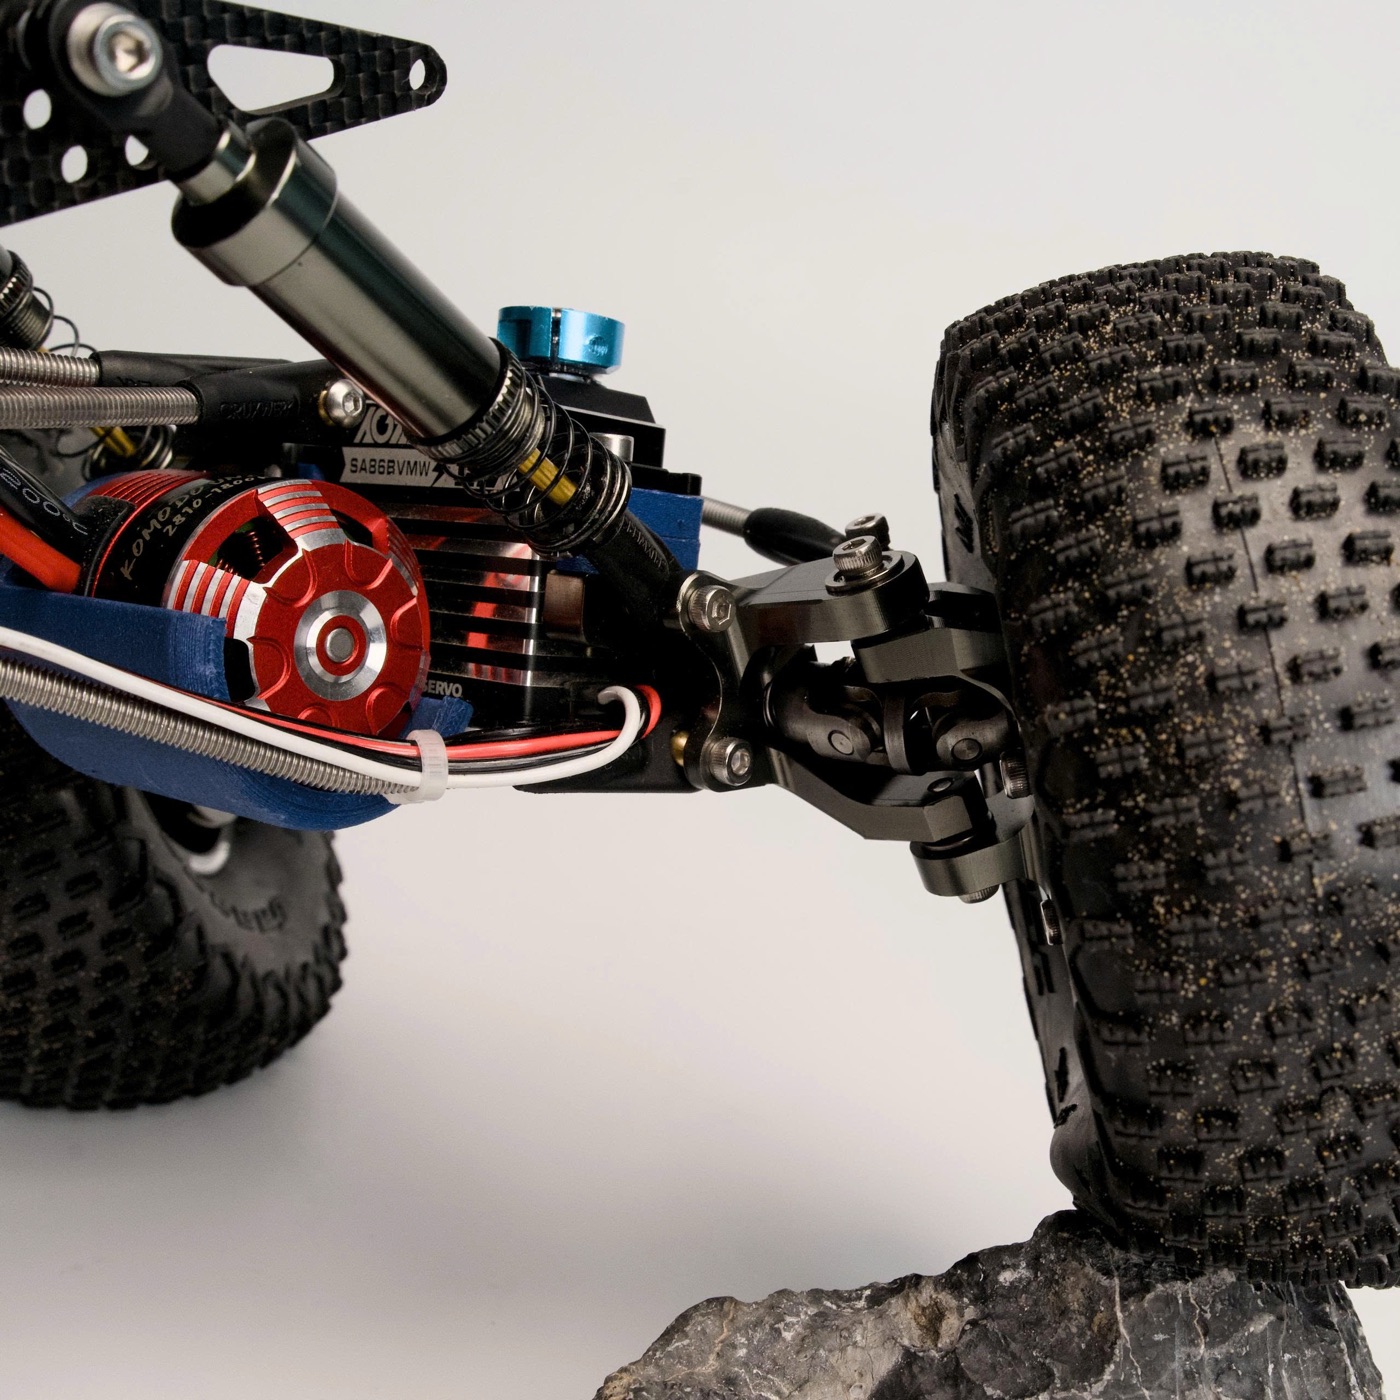
Go where others can't. Lock angles well past what a conventional axle allows, so the line you pick is the line you take.
02/True Double-Joint CV Driveshafts
Smooth power at extreme steering angles. No binding, no pulsing — torque stays even through the whole sweep.
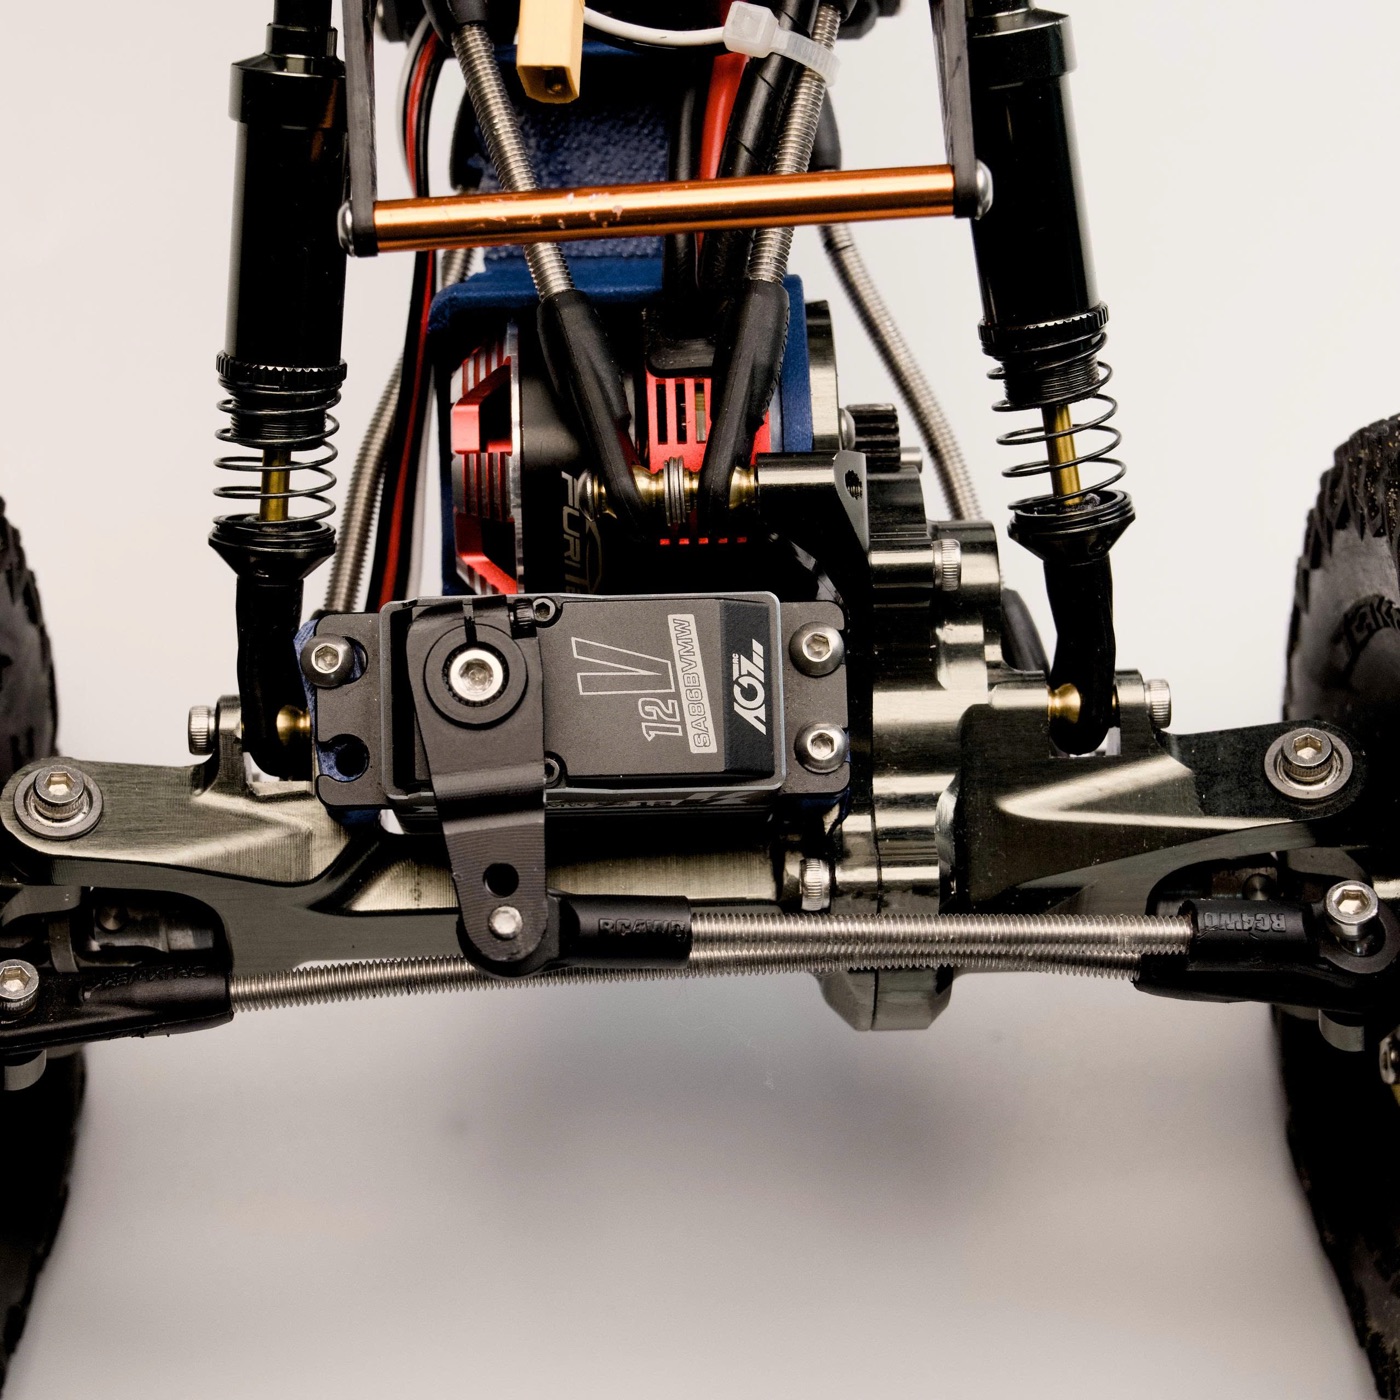
03/Integrated Servo Mount
Precision steering with maximum rigidity. The servo becomes part of the axle structure instead of hanging off it.
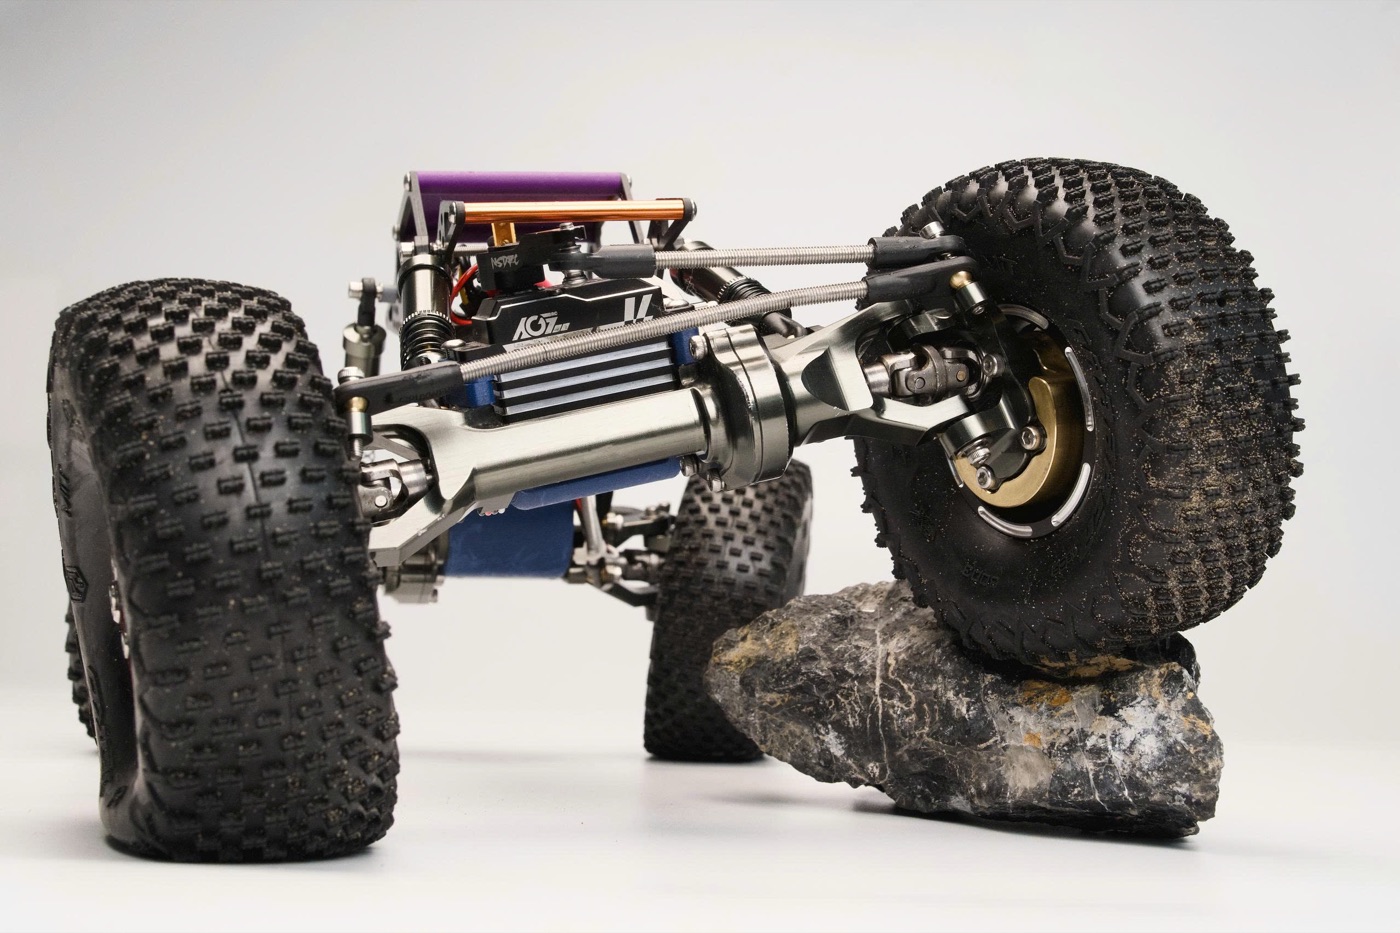
04/Optimized Portal Reduction
Higher clearance, greater wheel torque and reduced drivetrain load — the three things a competition crawler cannot trade away.
05/
Straps on.Walks in.
The best rock never sits next to a car park. Monty is built to travel on your back — over the pass, down the scree, into the line nobody else bothers to reach.
Take it anywhere. Crawl everything.
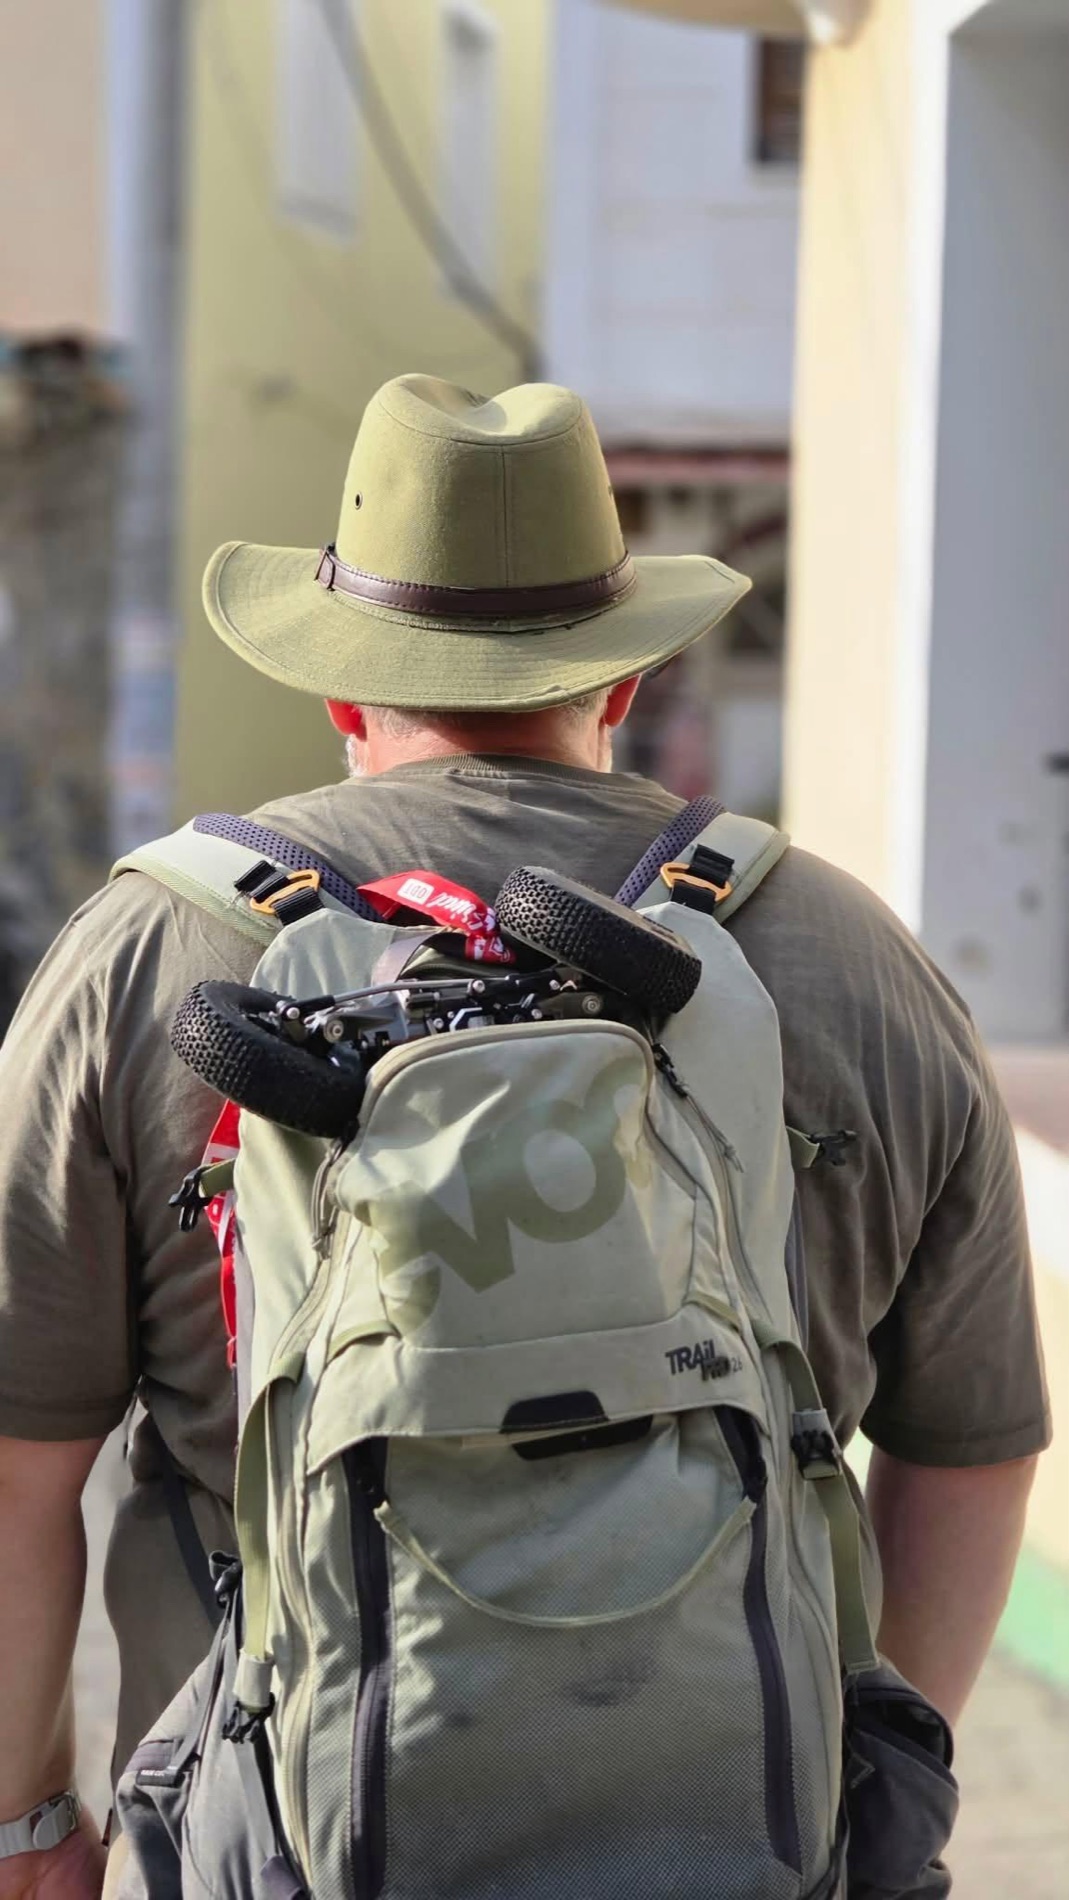 Backpack crawler / the walk in
Read it fromevery angle.
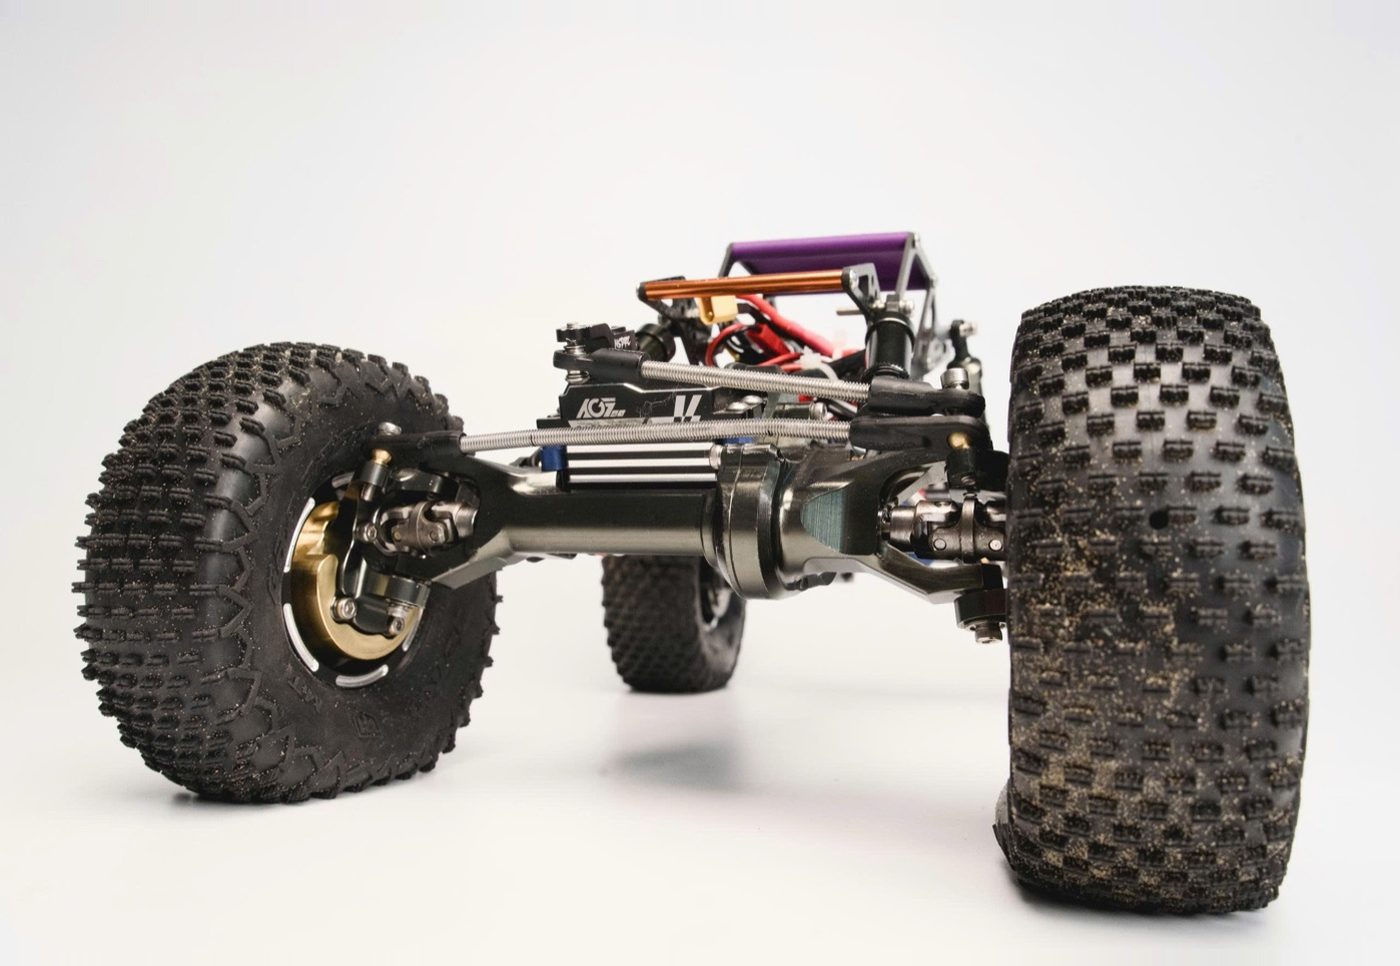 01/ Side profile
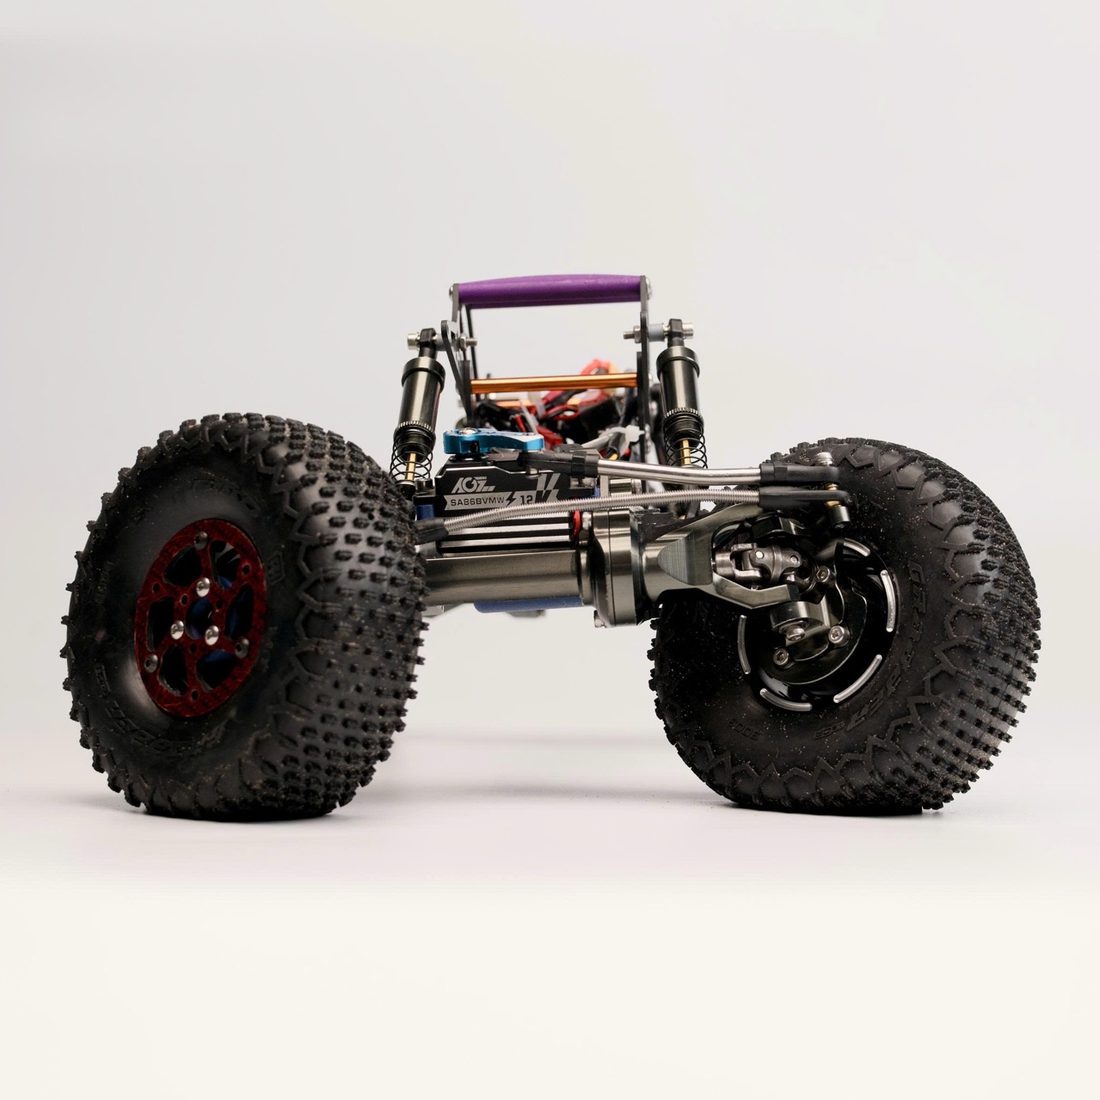 02/ Head on
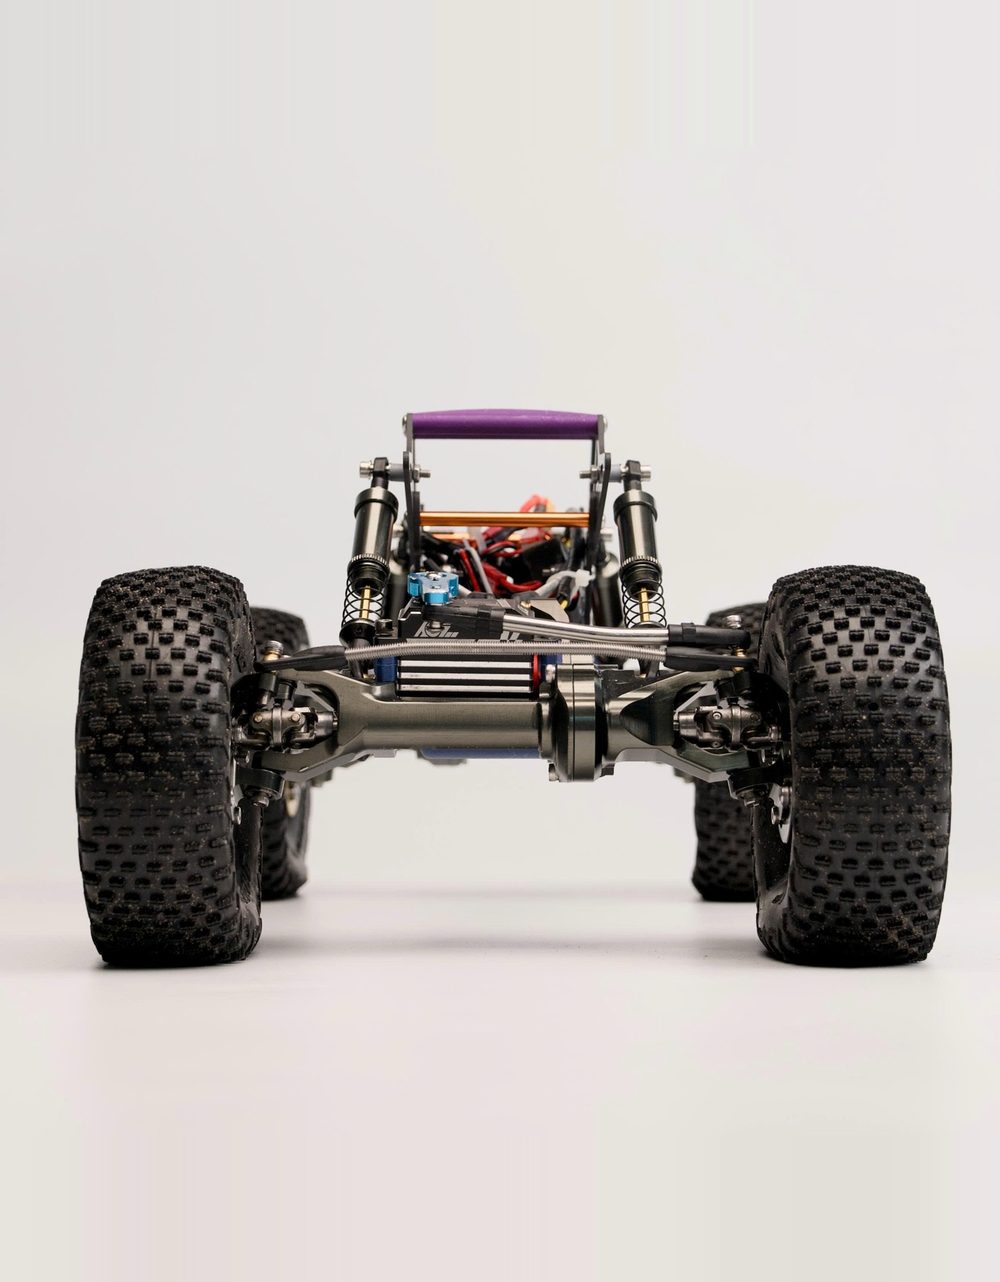 03/ Front geometry
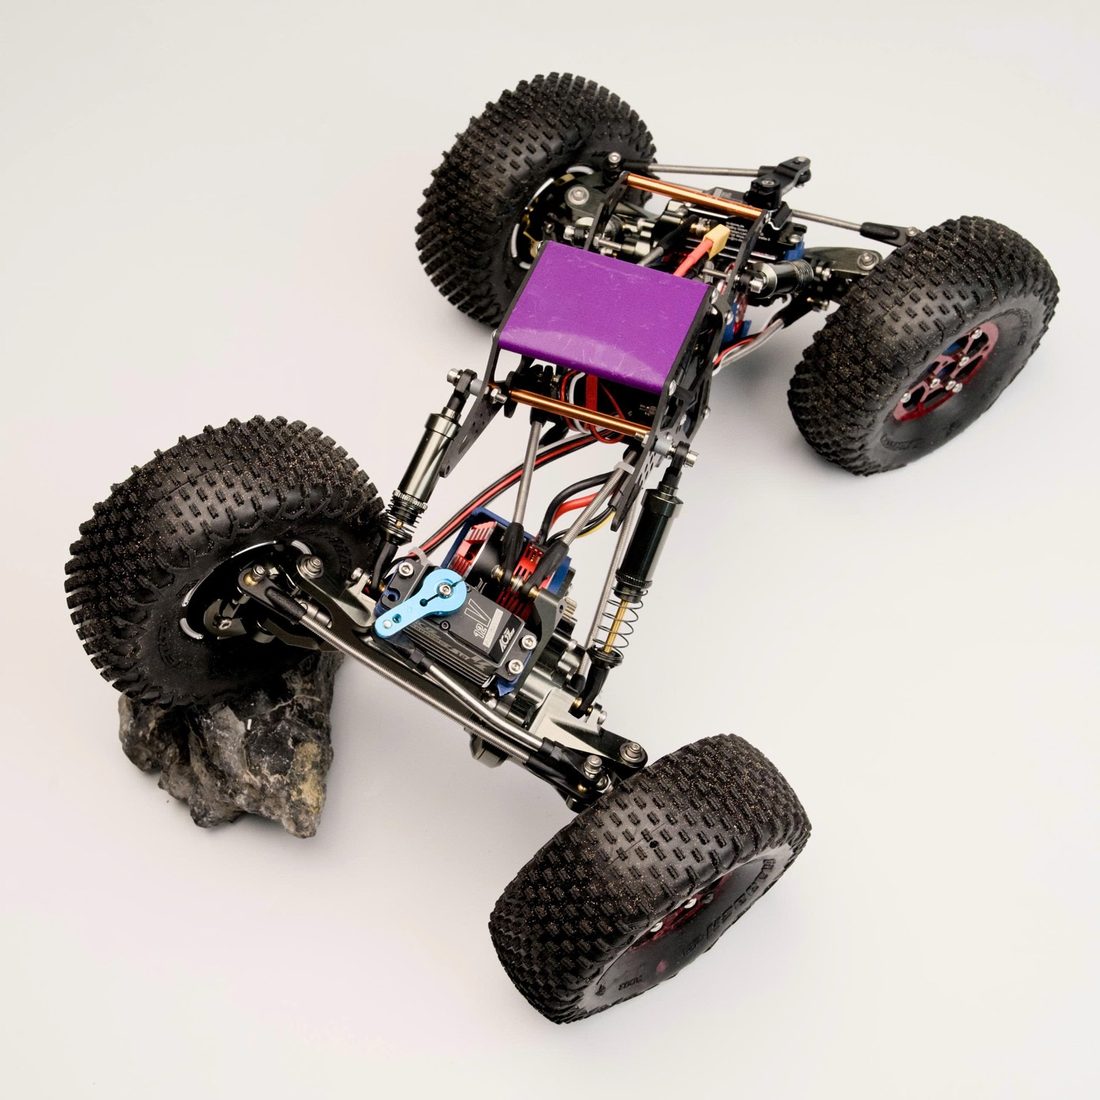 04/ Articulation
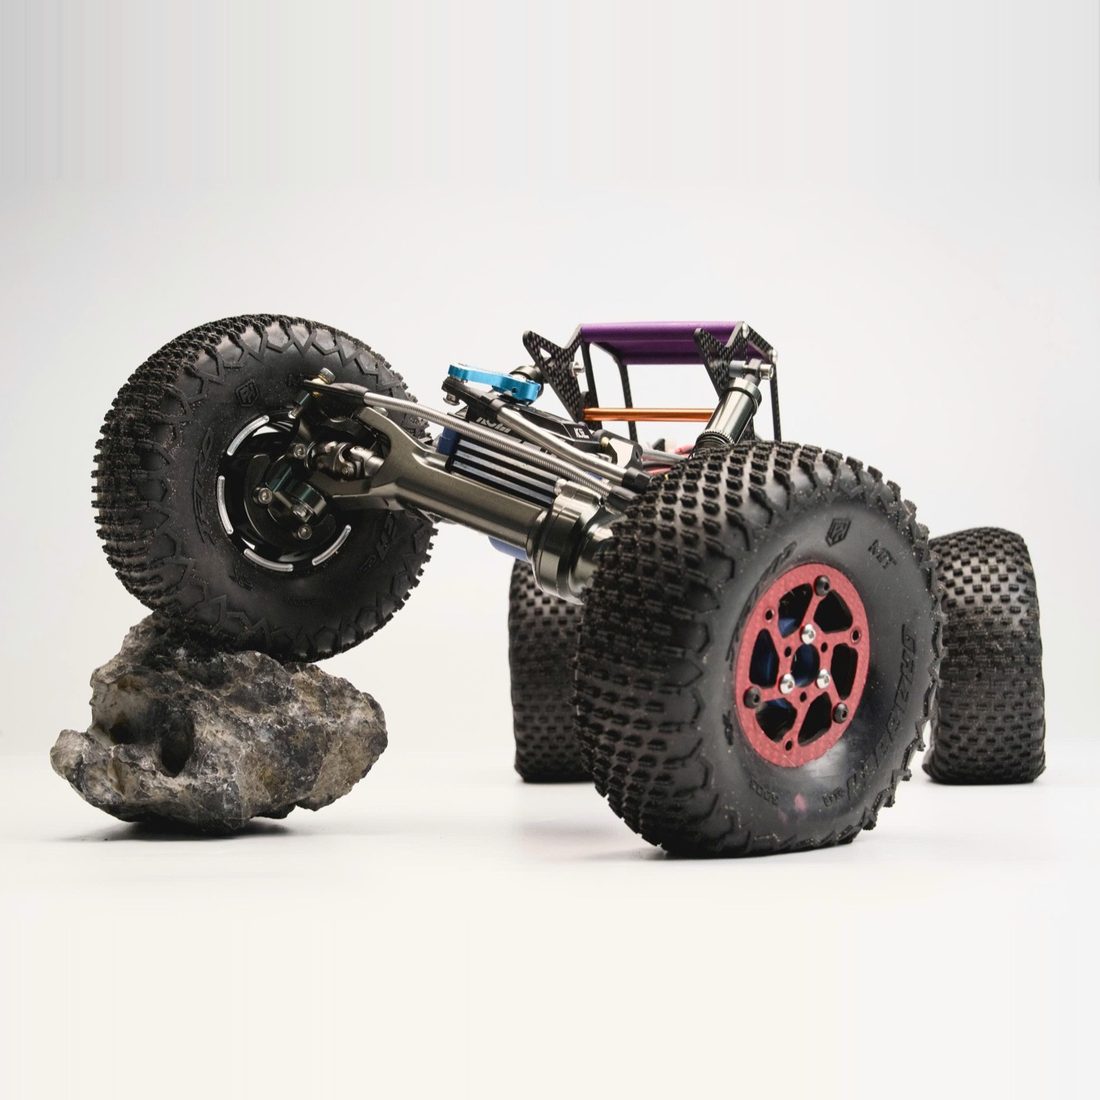 05/ Wheel load
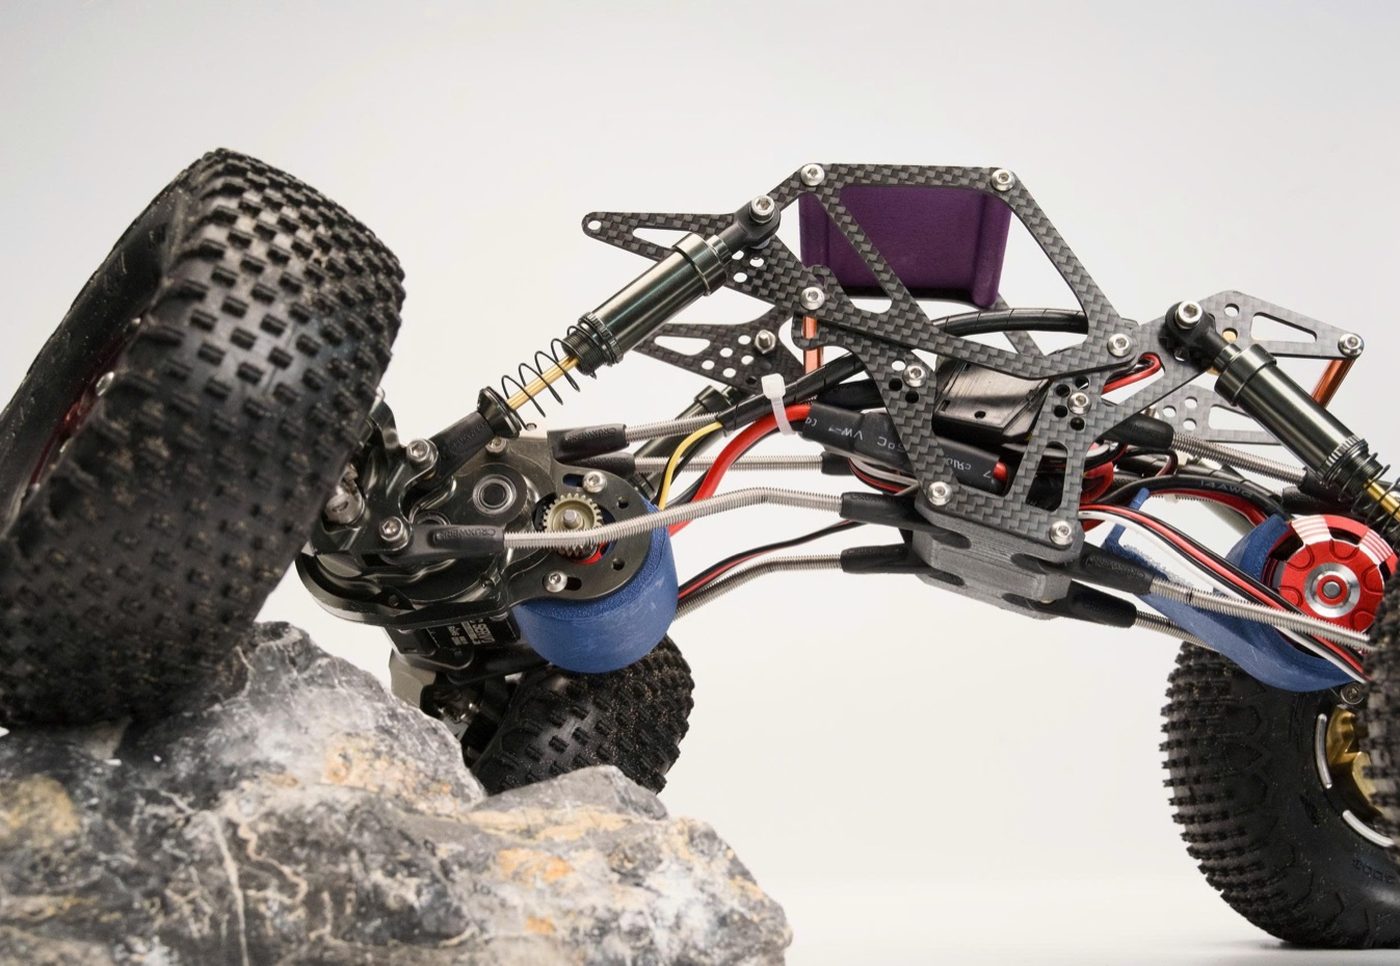
Related Products
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Recently Viewed Products
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Example product title
- $999.99
- $999.99
- Unit price
- per
Brands We Distribute


- Choosing a selection results in a full page refresh.